Pi-Rover
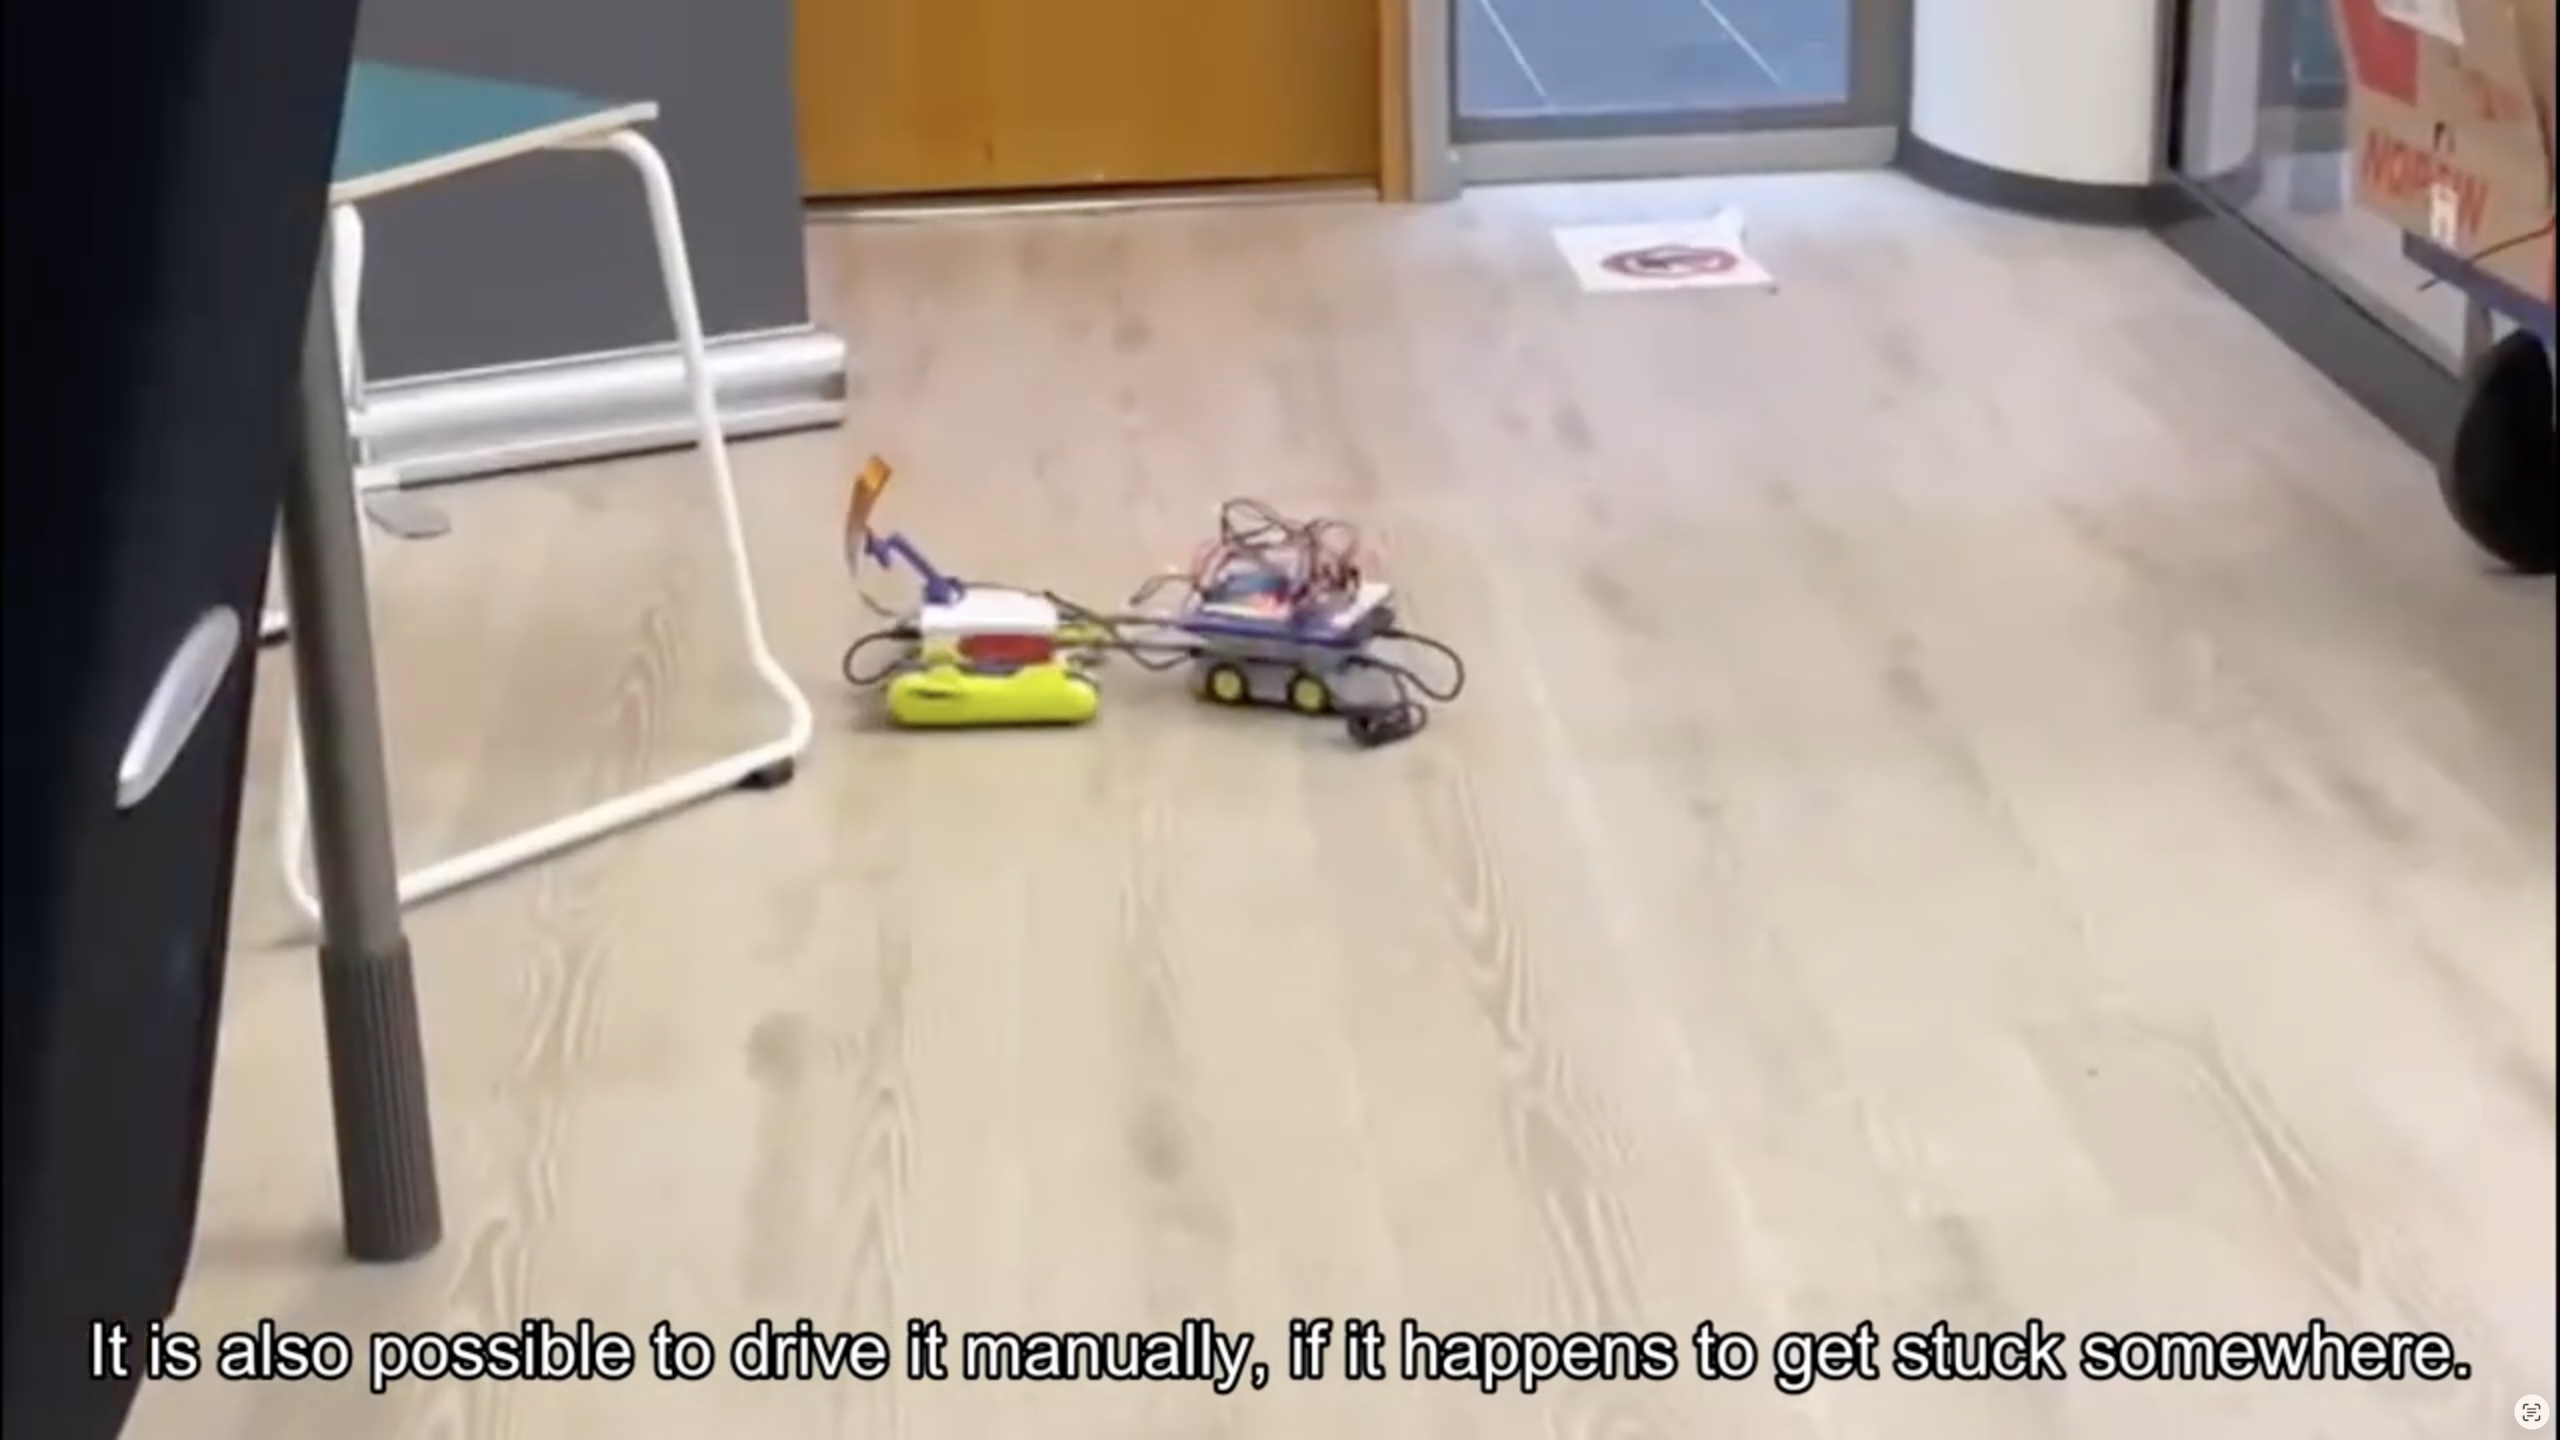
Pi-Rover is an autonomous robot that navigates difficult-to-reach spaces using computer vision and object recognition. It detects obstacles, recognizes objects, and operates entirely offline without external communication.
Use Case
Exploration of confined, difficult-to-reach spaces where human access or radio communication is limited. Potential applications include industrial and mining environments, as well as autonomous inspection scenarios where offline operation is essential.
Target Audience
Mining and defense industries, robotics researchers, and organizations exploring autonomous navigation and inspection in environments with limited connectivity.
How It Works
Pi-Rover uses computer vision and object recognition to analyze its surroundings while navigating autonomously. It detects obstacles and adjusts its movement to avoid them. The rover can also identify objects encountered along its route and record information about its environment. All operations are performed locally without relying on external network connections.
User Journey
Technologies
Computer vision, object recognition, autonomous navigation, obstacle detection and avoidance, offline processing
Author
Niklas Auranen, Max Jauhiainen
Project
GPT-Lab Summer Internship 2026